Mixture of Frames Policy: Multi-Frame Action Denoising for Bimanual Mobile Manipulation
Conference on Robot Learning (CoRL) 2026
CoRL 2026 The UMI Arena Workshop (Spotlight)
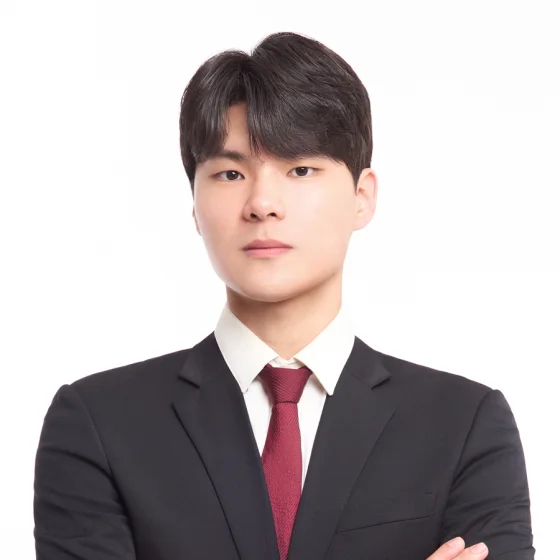
I am a Stanford MSCS student and robotics researcher at the IPRL Lab & REAL Lab, where I am co-advised by Jeannette Bohg and Shuran Song. I am fortunate to be directly mentored by Dian Wang and to work closely with Xiaomeng Xu and Han Zhang. Before Stanford, I spent 1.5+ years as a Research Scientist at KAIST. My research focuses on data-efficient and generalizable policy learning for long-horizon bimanual mobile manipulation.
Prior to my research path, I co-founded three startups, gained strategic consulting experience at McKinsey & BCG, and majored in Business Administration and Computer Science. This background motivates my focus on translating robotics research into practical, impactful products.
Conference on Robot Learning (CoRL) 2026
CoRL 2026 The UMI Arena Workshop (Spotlight)
Robotics: Science and Systems (RSS 2026)
IROS 2026 Bimanual Robot Learning Workshop (Best Paper)
IROS 2026 ScaleInfra Workshop (Best Paper)
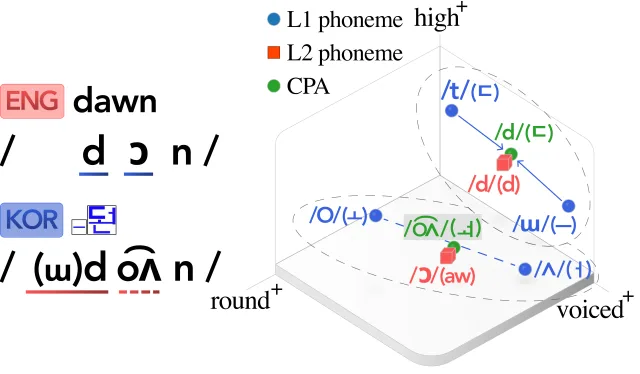
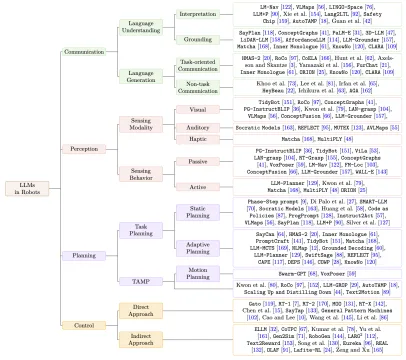
Intelligent Service Robotics, 2024
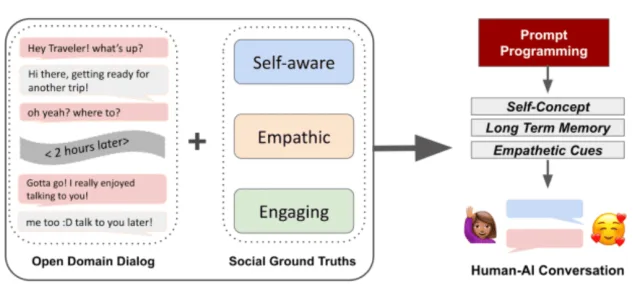
Proceedings of the 44th Annual Conference of the Cognitive Science Society, 2022
* Equal contributions.
Skills: ROS2, Behavior Trees, YOLO, SAM, IK, Dynamic & Semantic 3D Scene Graphs
Engineered a real-time ROS2 framework for reactive mobile manipulation by parallelizing YOLO/SAM-based 3D scene graph construction and IK-based control via multi-threaded Behavior Trees.
Skills: Simulation Benchmarking, LLM-based Task Planning
Developed a framework-agnostic benchmark setting for evaluating diverse LLM/VLM-based task-planning frameworks across 100 interruption scenarios in AI2-THOR.
Skills: ROS2, Behavior Trees, MoveIt, Open3D, Force-Torque Sensing, RGBD Sensing
Developed an adaptive manipulation framework combining force-torque-sensor-based collision recovery, 3D pose-driven action adaptation, and MoveIt/Open3D manipulability analysis in dynamic environments.
Skills: ROS2, RViz, Qt, NVIDIA Riva ASR, Natural-Language Grounding, 2D LiDAR
Developed a voice-based robot navigation framework through a Qt-based RViz plugin integrating NVIDIA Riva ASR, natural-language goal grounding on a 2D LiDAR map, and ROS2 navigation stacks.
The UMI Arena Workshop, CoRL 2026 · Spotlight Talk
Bay Area K-Robotics Group
|
Stanford University
M.S. in Computer Science
Sep 2025 - Jun 2027 (Expected)
Advisors: Jeannette Bohg and Shuran Song |
|
Seoul National University
B.S. in Computer Science & Engineering, B.B.A. in Business Administration
Mar 2017 - Aug 2022
Grade: GPA 3.90/4.00 (Summa Cum Laude) |